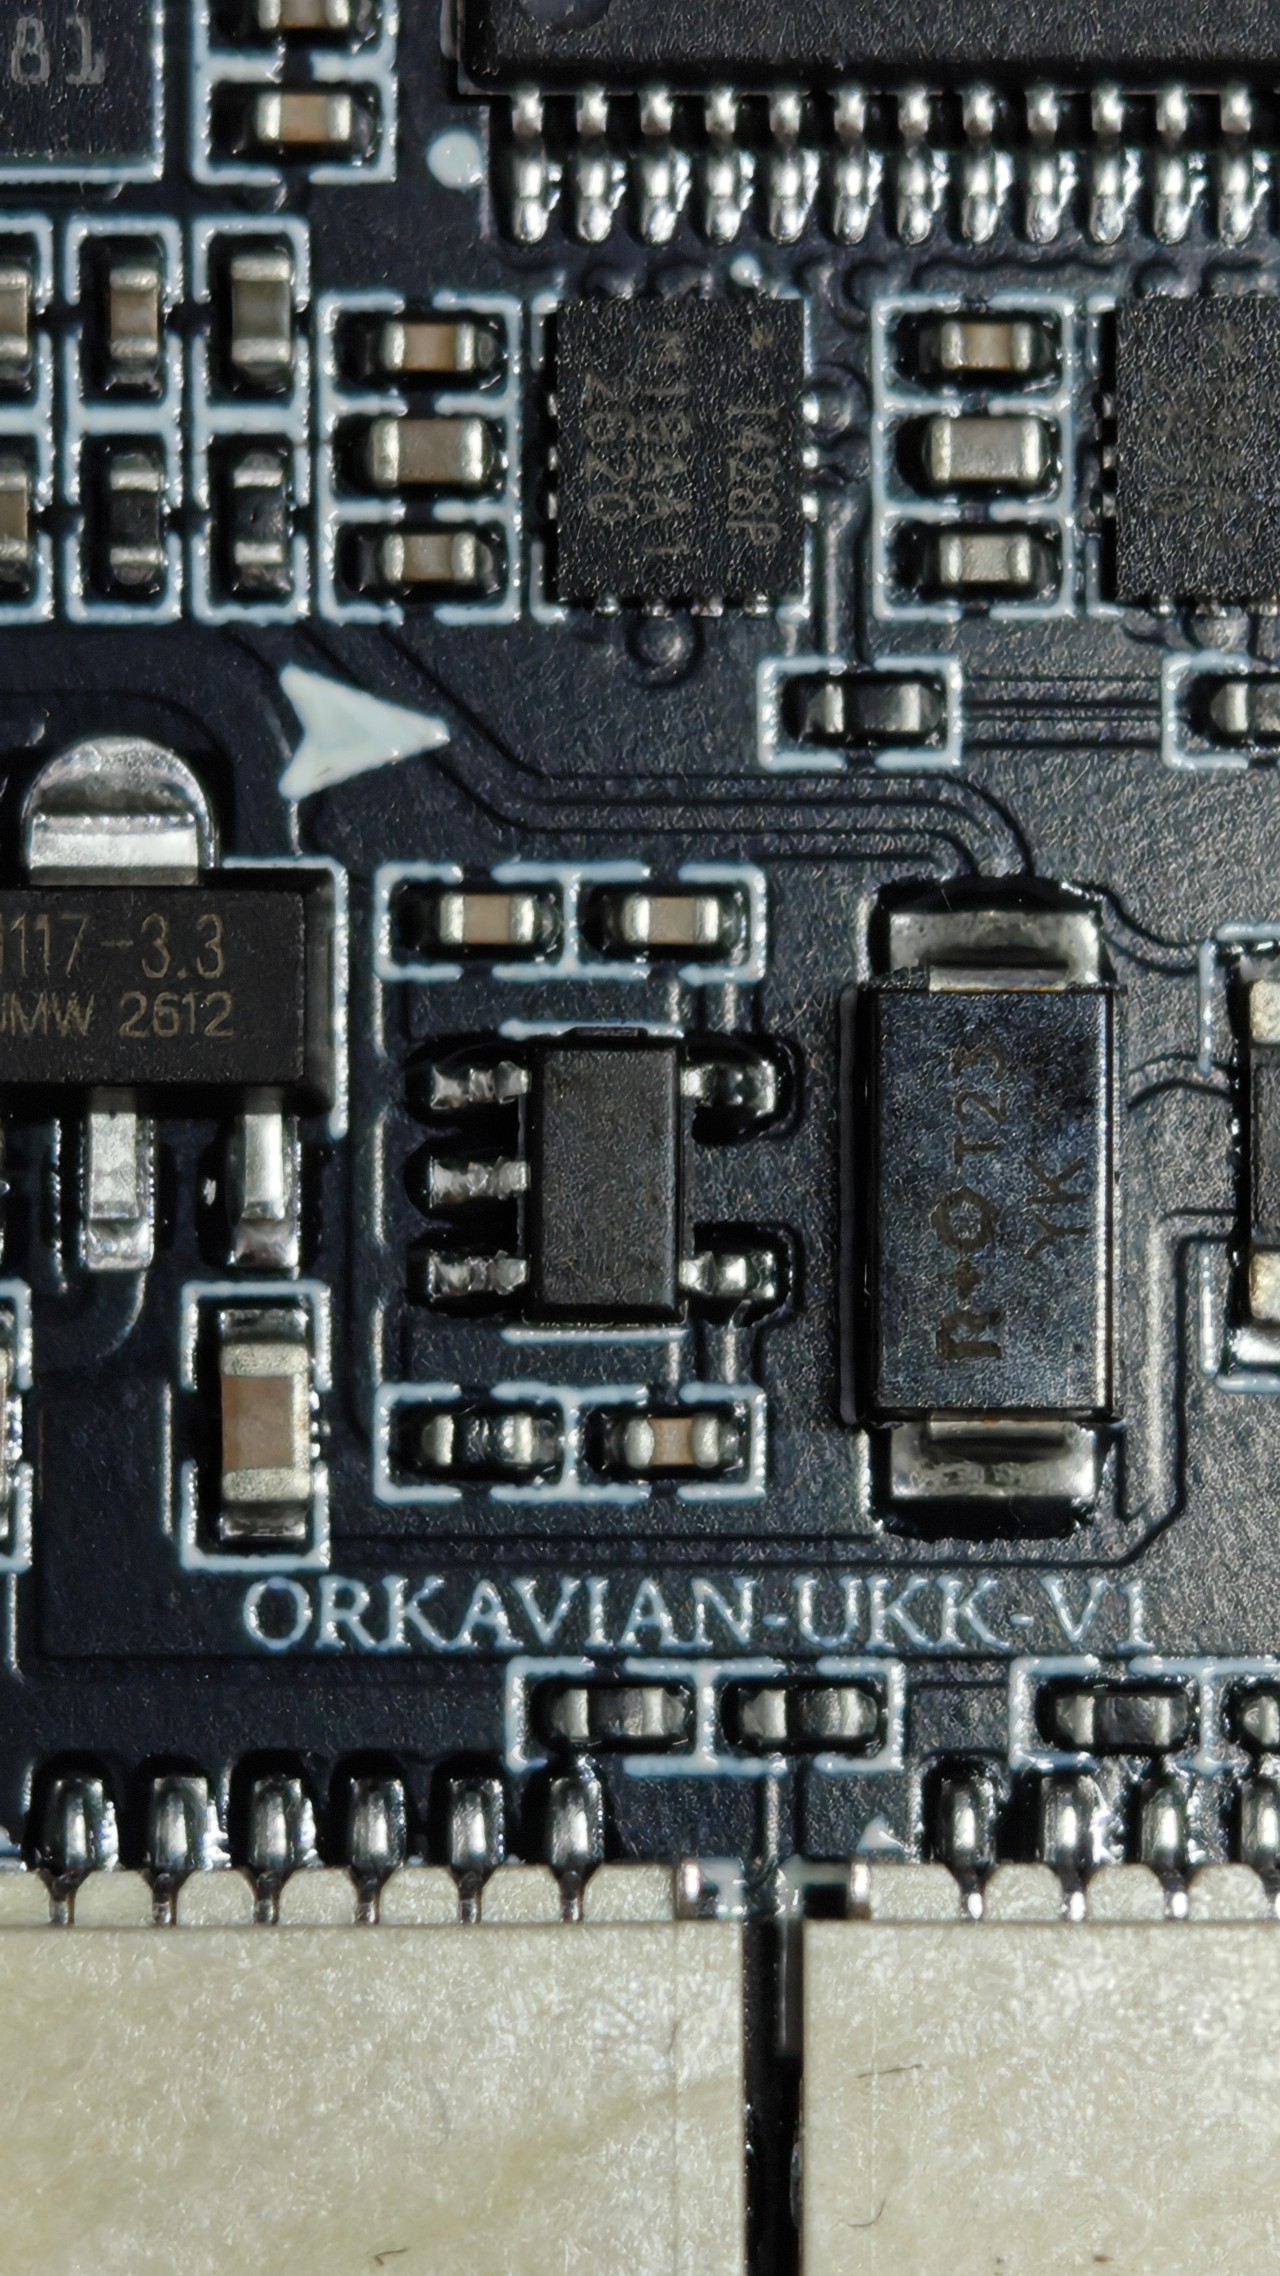
We have passed another important milestone. The first prototypes of the Orkavian UKK V1 flight controller are now ready.
We will now develop the drivers required for PX4 and ArduPilot. We will then integrate the board with Kaptan, the experimental flight-control firmware we are also developing in-house, and begin testing.
We have not yet introduced Kaptan in detail. By developing UKK V1 and Kaptan with the same engineering approach, we aim to establish an integrated flight-control foundation.
Kaptan is still at an early stage of development. We are aiming for a simpler architecture that can run on lower-cost, resource-constrained systems, with fewer opportunities for defects than existing flight-control firmware.
We hope to share the technical details and first test results soon.