Dual-core processing
The specified processor configuration targets up to 1 GHz on the Cortex-M7 and 400 MHz on the Cortex-M4. The design includes 2 MB of on-chip RAM, 64 MB of external NOR flash and 32 KiB of FRAM.
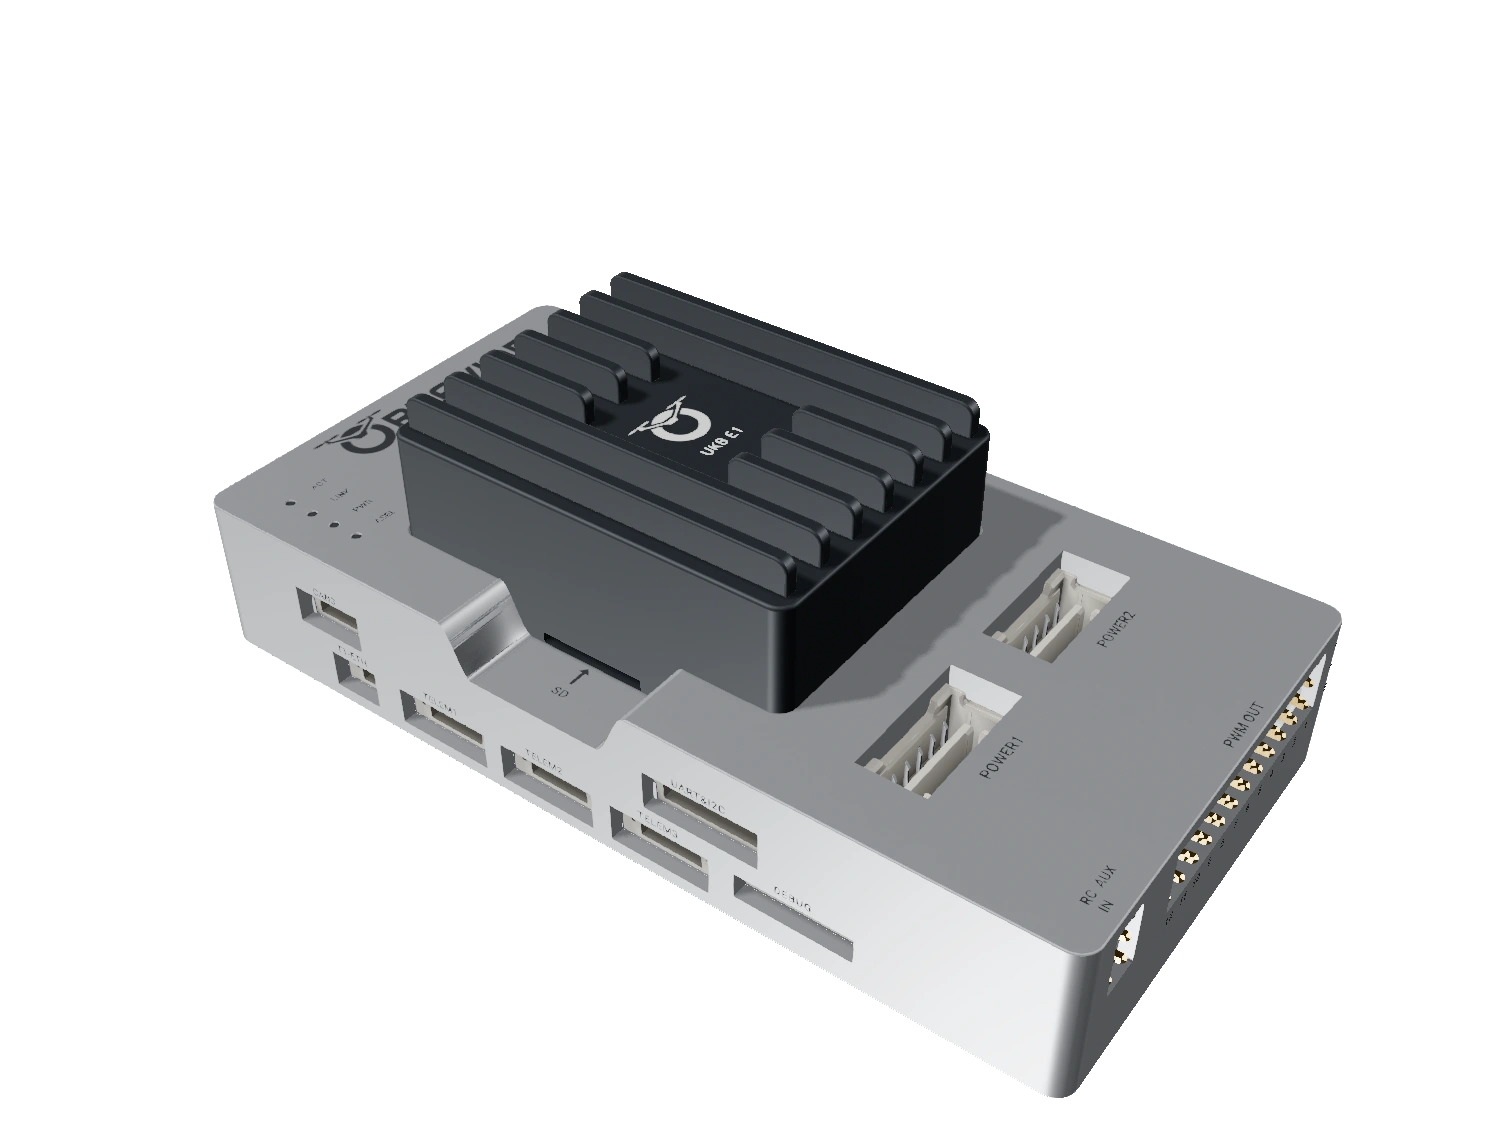
UKB-G1 is a general-purpose flight-controller design based on Pixhawk v6X-RT. Its i.MX RT1176 configuration targets a 1 GHz Cortex-M7 and a 400 MHz Cortex-M4 in a 3D-printed polymer enclosure. Three IMUs, dual barometers, 12 PWM outputs and dedicated GPS, telemetry, CAN and Ethernet connections support vehicle integration.
Loading the 3D model…
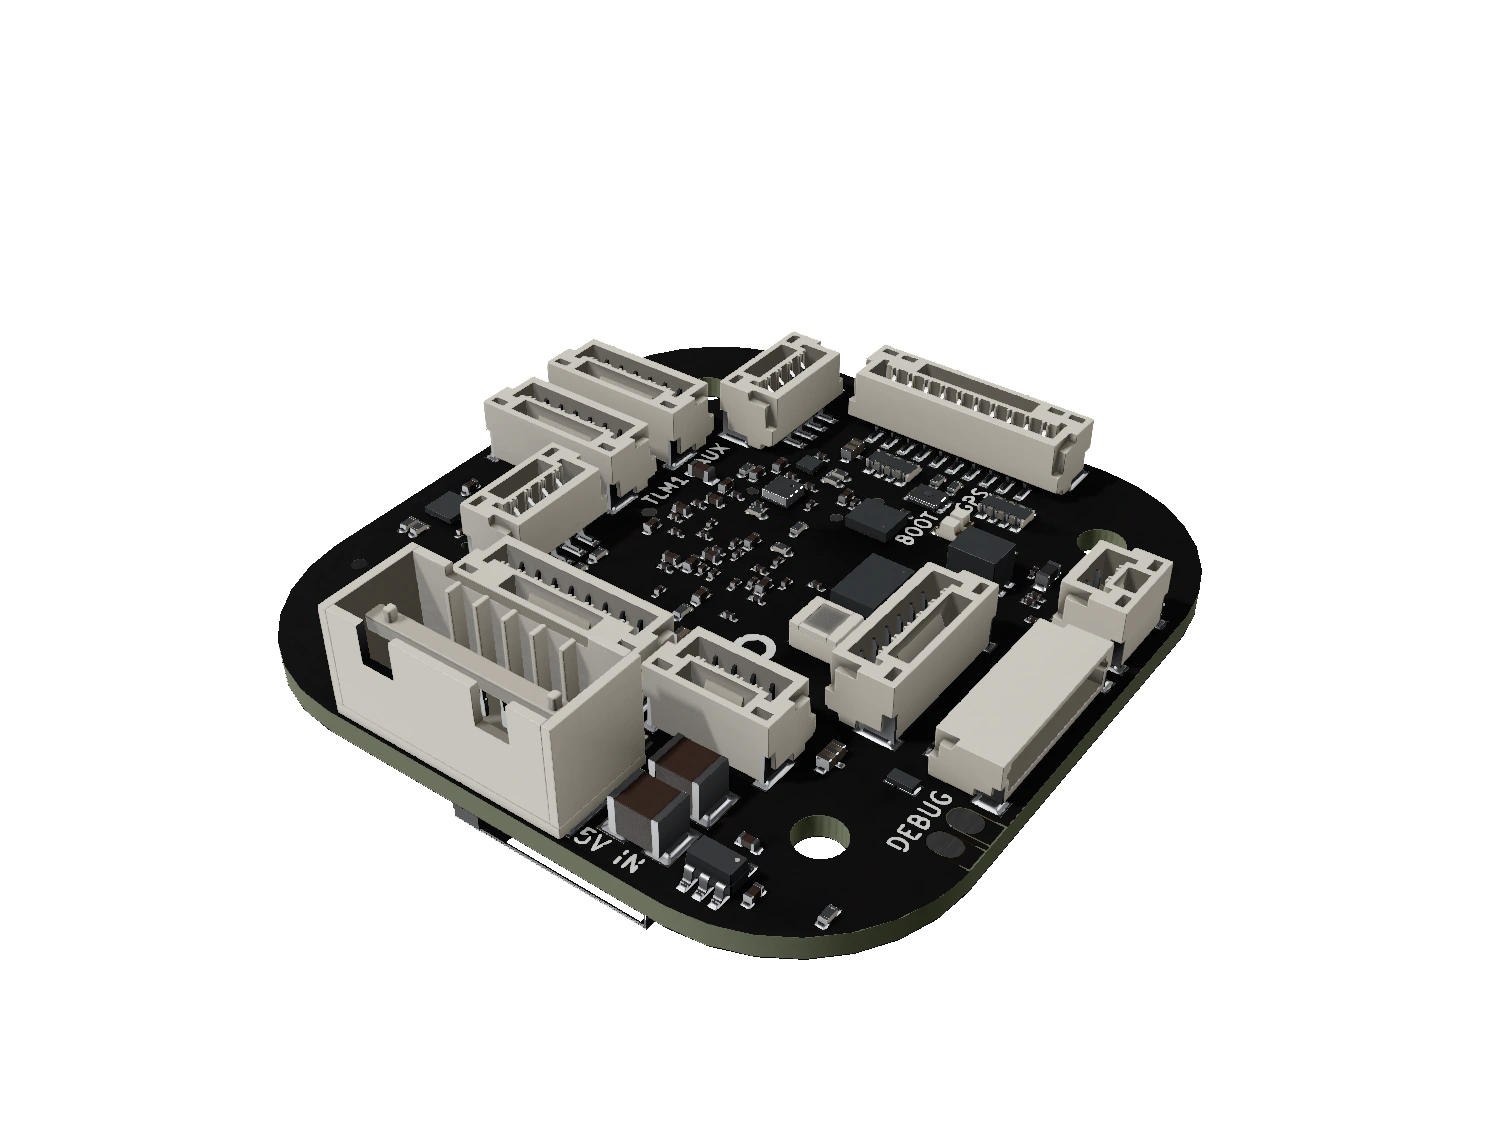
G1 interior: the shared electronics layout is shown; the G1 processor variant is not represented.
01 / ENGINEERING ADVANTAGES
The specified processor configuration targets up to 1 GHz on the Cortex-M7 and 400 MHz on the Cortex-M4. The design includes 2 MB of on-chip RAM, 64 MB of external NOR flash and 32 KiB of FRAM.
Two ICM-45686 IMUs and a BMI088 supply inertial measurements. Dual BMP390 barometers and a BMM350 magnetometer add pressure and magnetic-field sensing, with a separate vibration-isolated sensor assembly.
The polymer enclosure has a flat controller cover and dedicated openings for the fixed connector layout. Its 94.9 × 48.9 mm footprint accommodates the controller, sensor assembly and carrier, with access to the microSD card and USB-C connection.
ALSO IN THE RANGE